Contact Sales

Physical AI · Data services

The real world isn’t easy.

HumanSignal creates novel datasets around the exact environments, actions, sensors, and edge cases your robots need to learn.

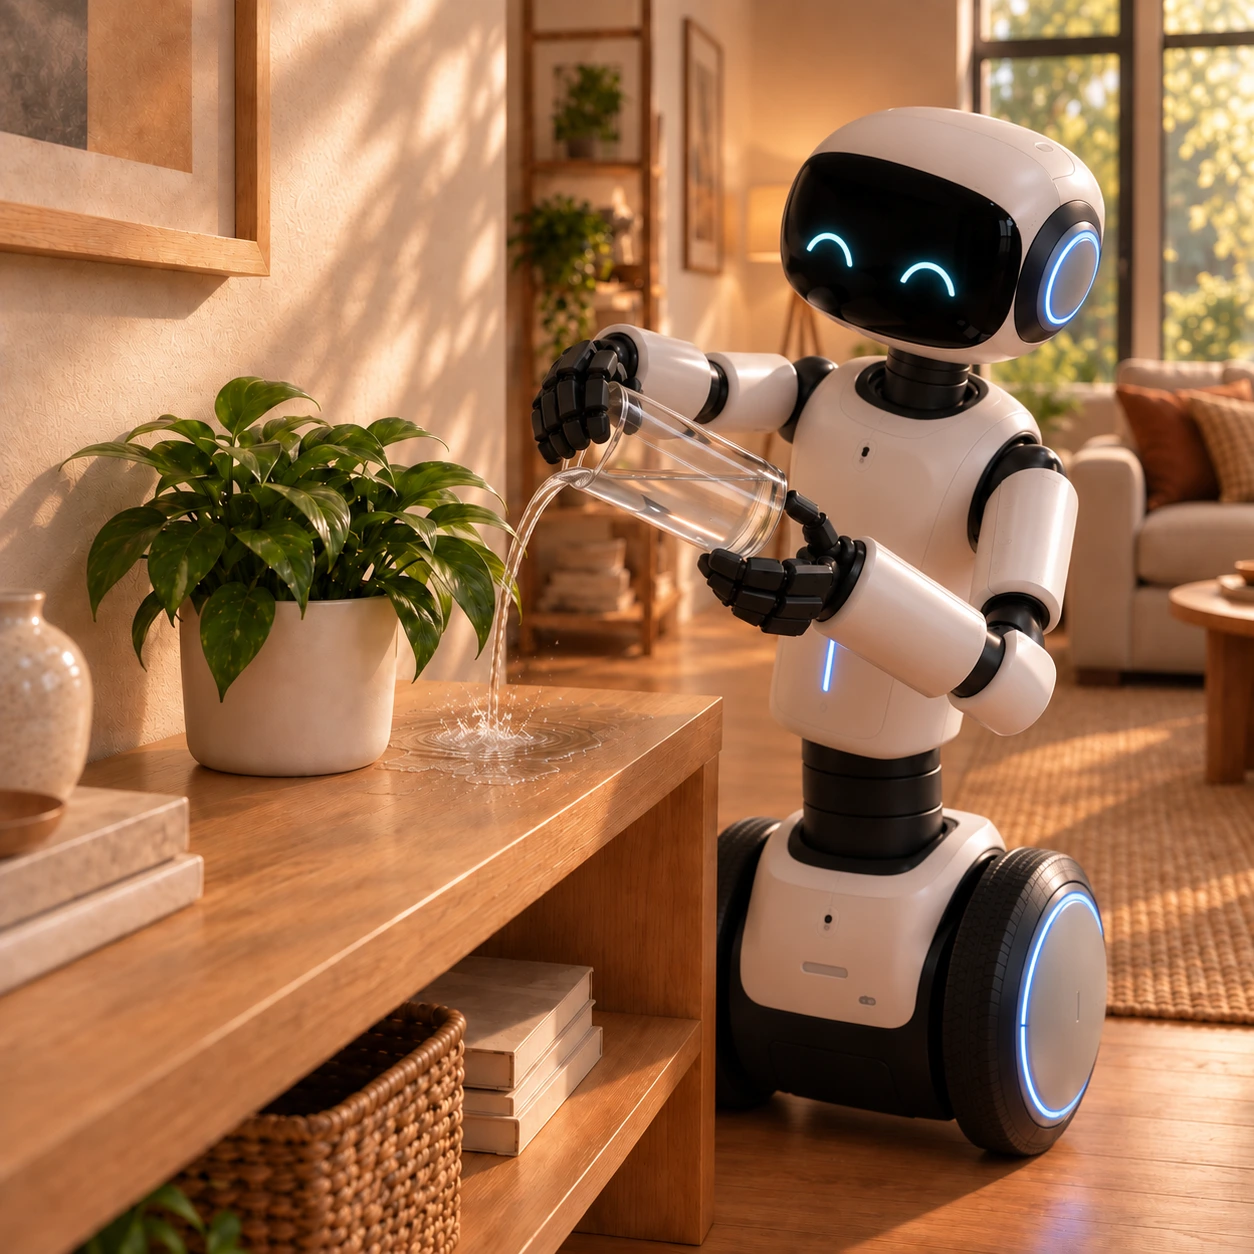
Wheeled robot close to a table, watering beside a small planter while the water stream lands on the console

HumanSignal Data Services

Specialists in novel datasets.

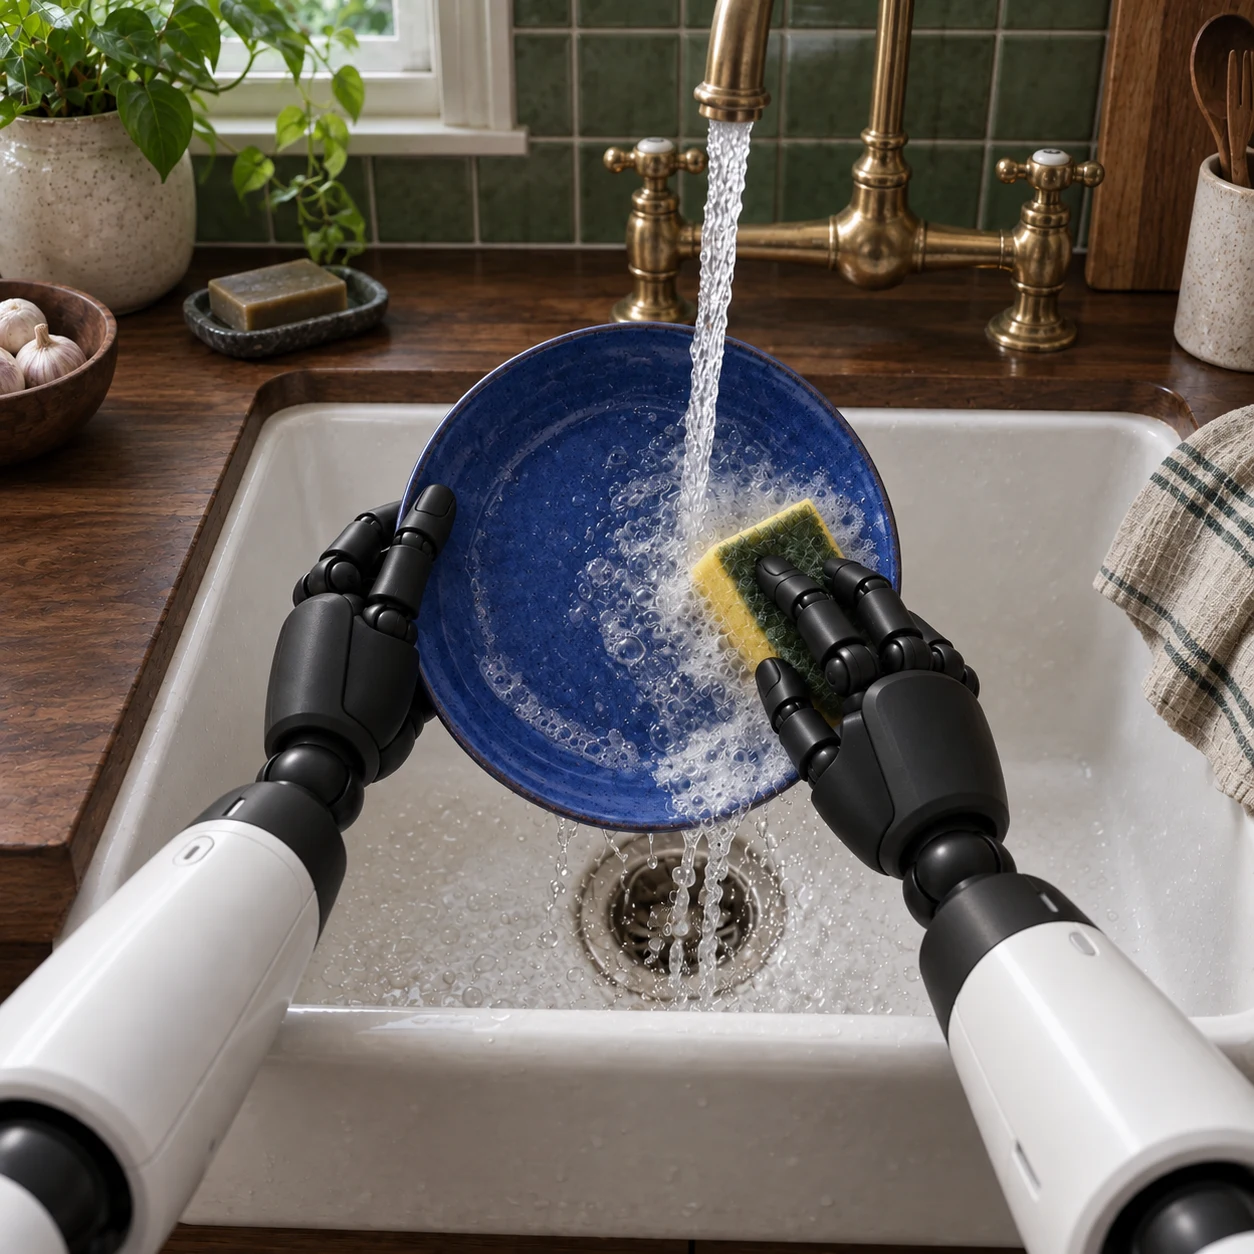
We turn human demonstrations into structured training examples, with the action boundaries, hand-object interactions, and taxonomy your pipeline expects.

Human demonstrationFrame 0184
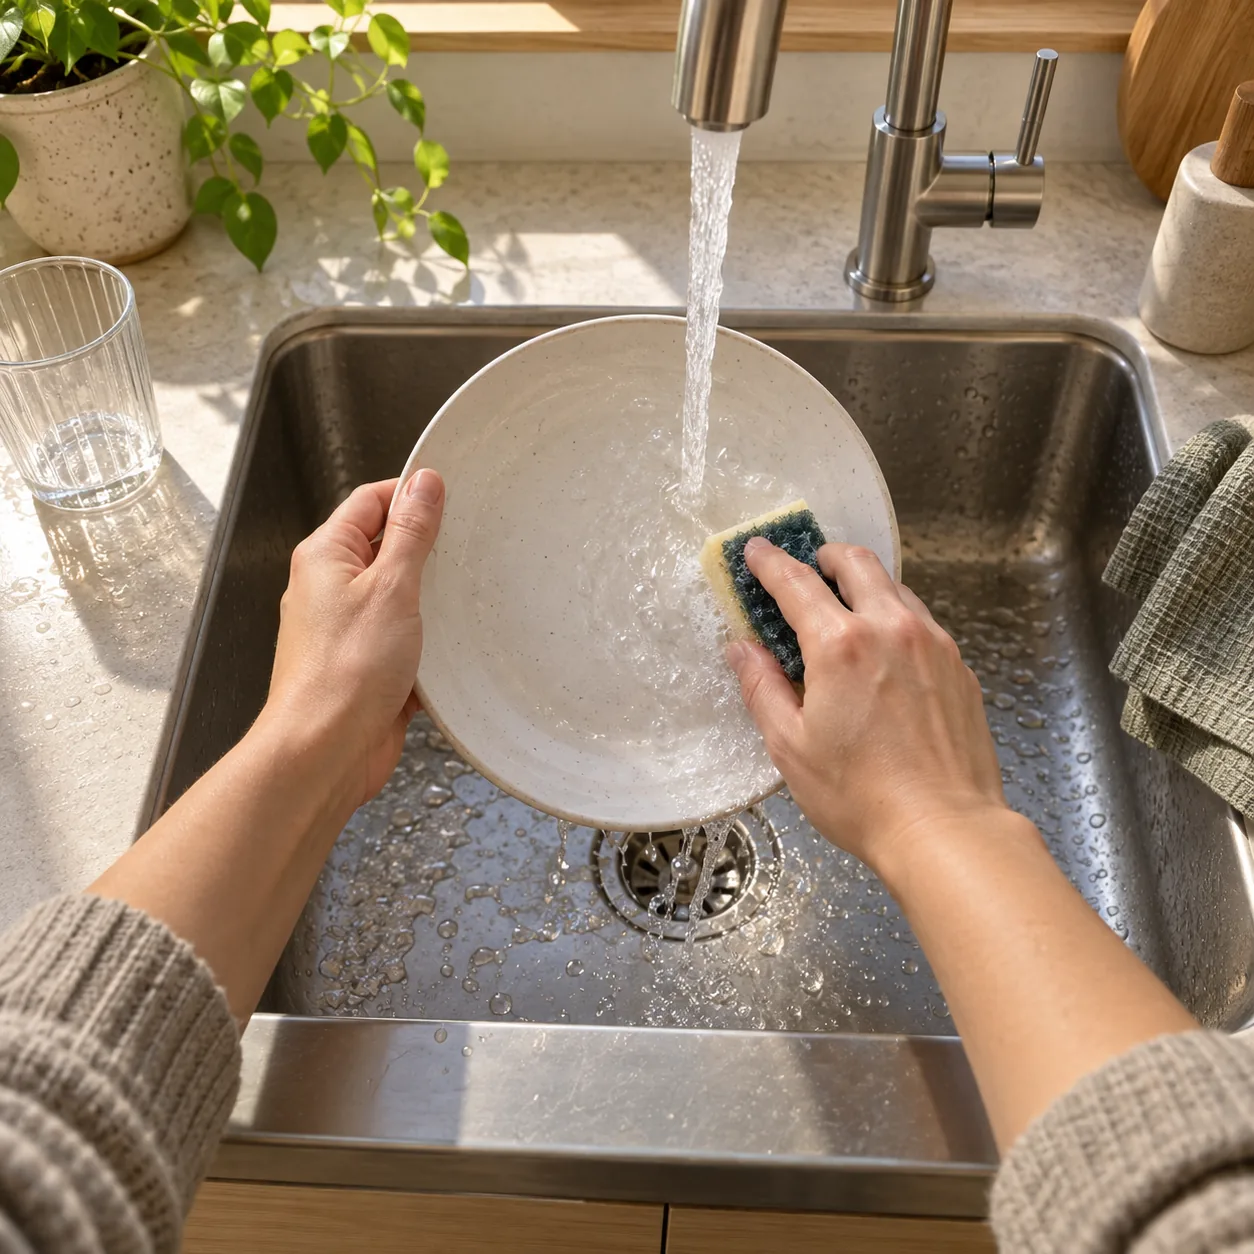
First-person view of a person washing a plate
Hand · L
Hand · R
Plate
Robot actionCorrespondence 0.94
First-person view of the robot's black articulated hands washing a blue plate in a different kitchen
Gripper · L
Gripper · R
Plate

From capture to training data

Precise data capture paired with precise annotation.

As the creators of Label Studio Enterprise, we build advanced annotation interfaces and custom rubrics that turn complex requirements into consistent, high-quality labels.

Data collection

Capture exactly the data you need. Two ways.

Use purpose-built environments in our secure facilities for precise control, or collect across diverse settings through our global contributor network.

Controlled collection

Controlled capture in our secure facilities.

We build and run purpose-built capture environments around your hardware, participant criteria, recording setup, and acceptance tests.
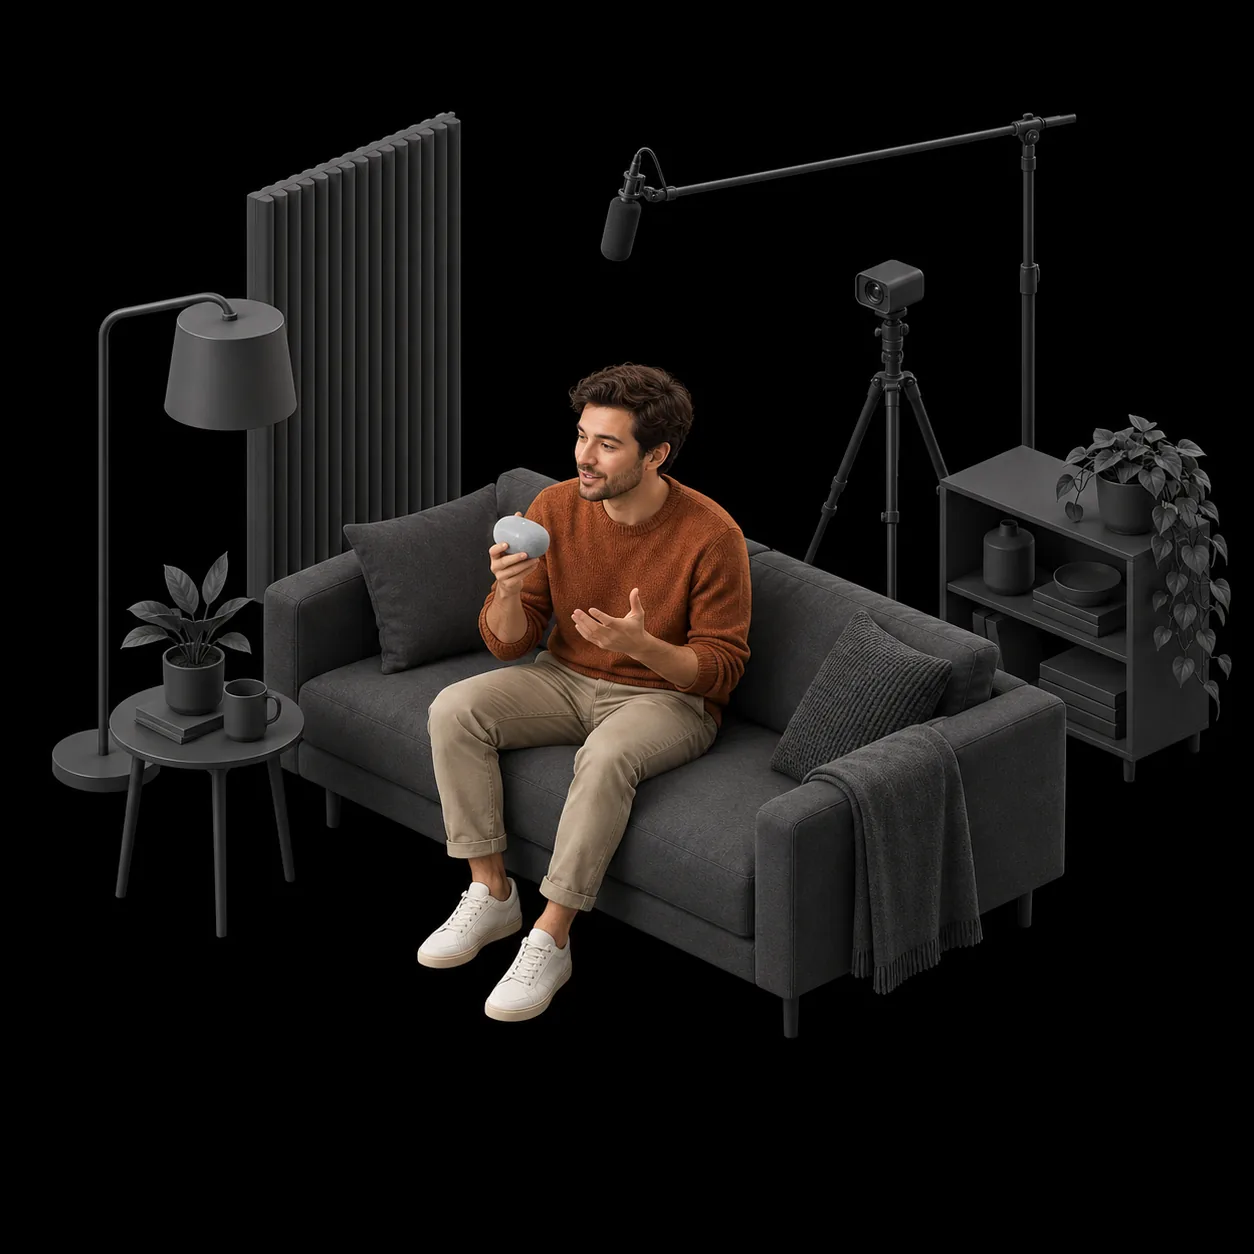
Purpose-built environments
Prototype hardware
Controlled light and audio
Synchronized sensors
Participant recruitment
Repeatable protocols
Participant speaking to a device in a controlled living-room capture set

Real-world collection

Diverse capture across real-world environments.

Our global contributor network collects across the homes, layouts, objects, people, and task styles your system will encounter outside the lab.
27
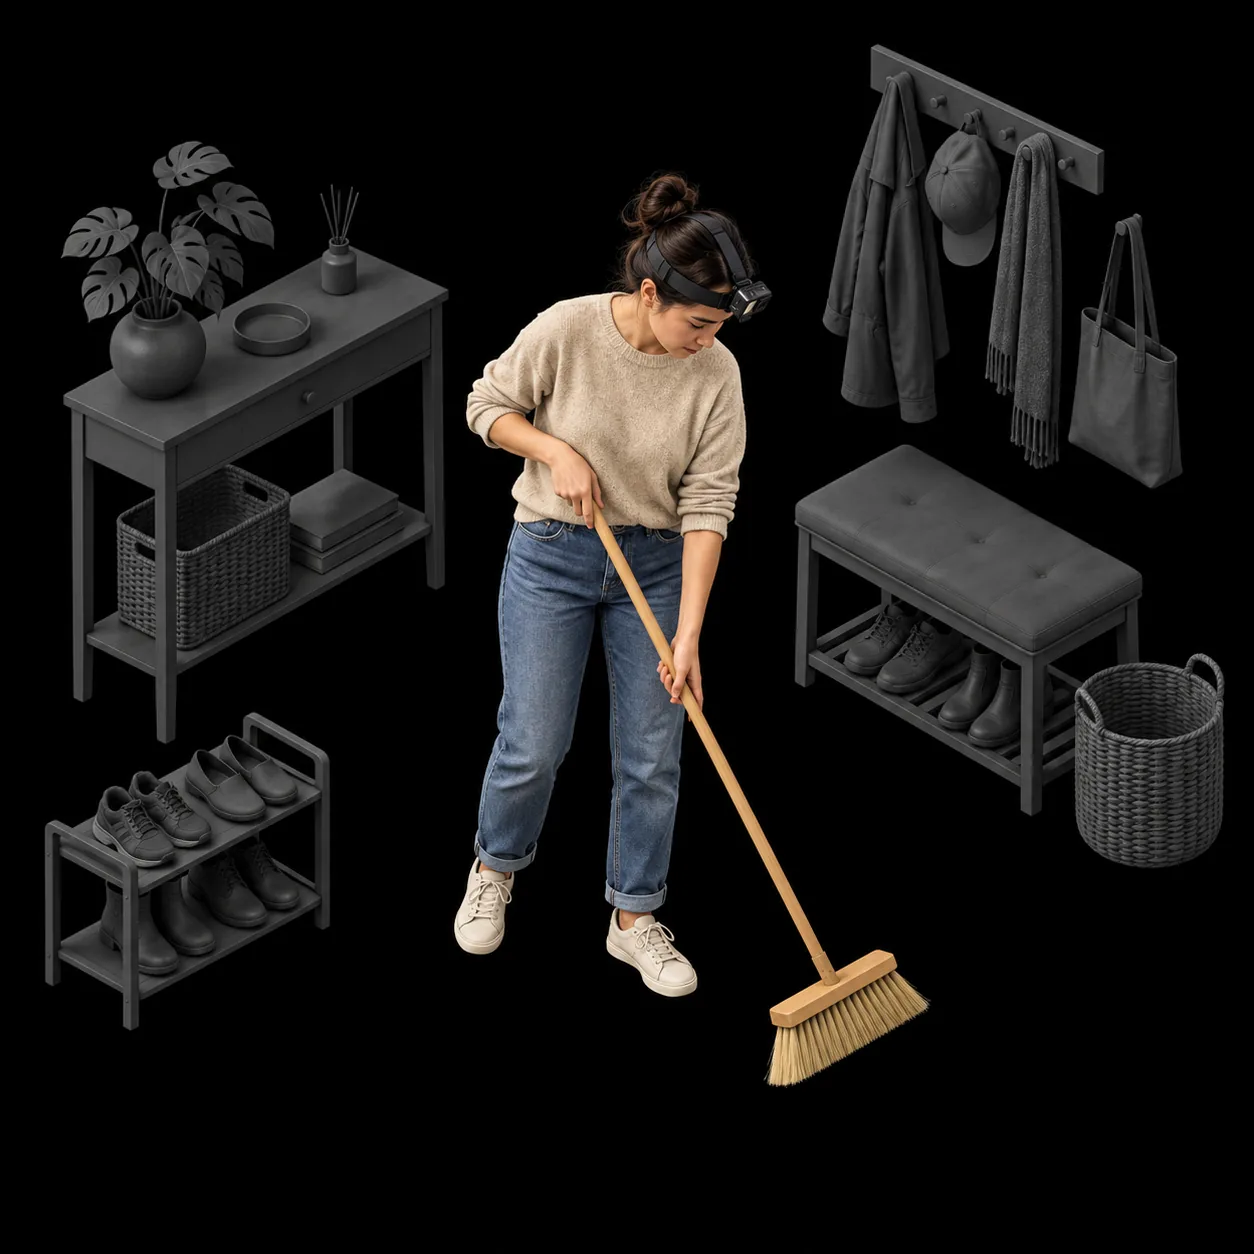
Household activities
1080p
Head-mounted POV
30fps
Continuous capture
Participant wearing a head-mounted camera while sweeping in a household environment
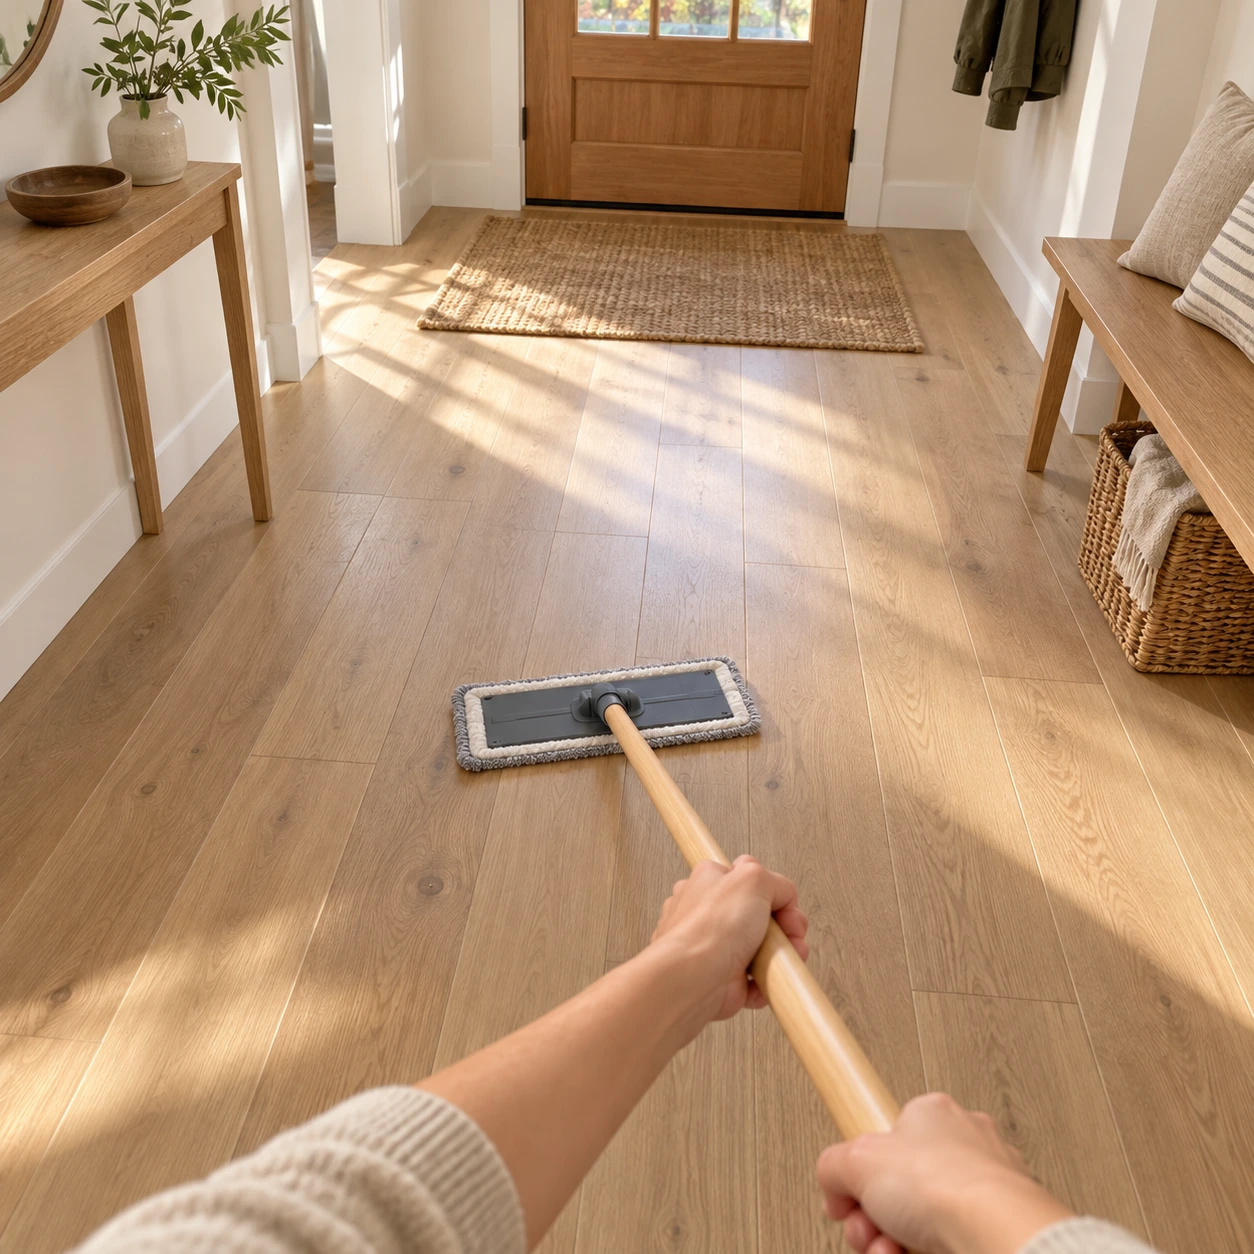
Captured POVHousehold 014
Head-mounted point-of-view of the participant mopping a household floor
  • Nigeria
  • Kenya
  • India
  • United States
  • Philippines
  • South Africa
  • Pakistan
  • Indonesia
  • Vietnam
  • Romania
  • Brazil
  • Canada
  • Colombia
  • United Kingdom
  • Turkey
  • Italy
  • Bangladesh
  • Morocco
  • Thailand
  • Argentina
  • Germany
  • Spain
  • Poland
  • Ghana
  • Egypt
  • Mexico
  • Malaysia
  • Ethiopia
  • Rwanda
  • Peru
  • Finland
  • Sri Lanka
  • Chile
  • Uganda
  • Tunisia
  • Netherlands
  • Tanzania
  • Greece
  • France
  • Ecuador
  • Portugal
  • Japan
  • Norway
  • South Korea
  • Nepal
  • Cameroon
  • Ireland
  • Zambia
  • Zimbabwe
  • Hungary
  • Austria
  • Serbia
  • United Arab Emirates
  • Australia
  • New Zealand
  • Algeria
  • Switzerland
  • Saudi Arabia
  • Jamaica
  • Moldova
  • Trinidad and Tobago
  • Singapore
  • Slovenia
  • Costa Rica
  • Czech Republic
  • North Macedonia
  • Hong Kong
  • Iceland
  • Panama
  • Dominican Republic
  • Mozambique
  • El Salvador
  • Slovakia
  • Uzbekistan
  • Sweden
  • Georgia
  • China
  • Honduras
  • Botswana
  • Bosnia and Herzegovina
  • Jordan
  • Kazakhstan
  • Ivory Coast
  • Mongolia
  • Nicaragua
  • Israel
  • Bulgaria
  • Denmark
  • Cyprus
  • Guatemala
  • Croatia

EgoChores sample dataset

Download a sample dataset.

Request a free one-hour sample of novel first-person household video, captured and annotated for dexterous hand-object manipulation.

01
Raw video Judge framing, lighting, household variation, and continuous task coverage.
02
Standard annotation Inspect temporal boundaries, hand-object interaction, and the published object taxonomy.
03
Custom annotation Talk to us about how your own object classes, edge cases, or proprietary schema can be applied to captured datasets.

Request the sample

Tell us where to send the EgoChores sample and which annotation depth you want to evaluate.
Wheeled robot beside the small planter, wiping spilled water from the console

Physical AI · Data services

Physical AI demands novel data creation.

Tell us what your robots need to learn. We will define the capture, annotation, and quality plan to build it.